BioPath Pitch Studio Pitch Safe

Decision Intelligence for Farm Pest Control

From map to measurable farm impact in under 2 minutes.

BioPath converts complex layouts into reproducible trap-placement decisions with simulation-backed proof. Built by Xiaoxiao Zhouyi, Founder & Sole Builder, PhD Candidate in stochastic processes.

Real farm context + synthetic geometry Stochastic modelling + Monte Carlo Currently applying CREGS + LINCAM PoC
2-min Demo Rhythm for tomorrow's live segment

0:00-0:30

Auto connect + health check.

0:30-1:00

Run solve on Cambridge map.

1:00-1:30

Run benchmark and read uplift.

1:30-2:00

Switch Pitch Mode and deliver ask.
Latest Run —
Capture —
Robust —
Trap Count 0
Uplift Run benchmark to compute uplift

Proof Panel

Use these values directly in your 10-minute narrative.

Benchmark Uplift: —

Heuristic Baseline Mean: —

Benchmark Status: No benchmark yet

Capture: nominal scenario estimate.

Robust: conservative score across uncertainty scenarios.

Weighted Mean: risk-prior weighted distance (can differ from plain mean).

Weighted mean uses photo-informed risk weights; it may differ from plain mean distance.

Summary link is optional for live pitch.

Loading baseline...

Pitch Mode Narrative

Problem -> Solution -> Proof -> Ask

Problem

Manual trap placement is experience-heavy, hard to standardize, and can miss bottlenecks in complex layouts.

Solution

BioPath converts one map into an optimized trap plan with reproducible, auditable coordinates.

Proof

With k=6 traps, BioPath reports optimized capture and robust capture with heuristic-baseline uplift under Monte Carlo validation.

Ask

We ask for 2 pilot introductions, one 8-week data trial, and support for a £5k-£20k LINCAM PoC application.

Funding Signal (official)

This section supports the finance criterion and your explicit funding pathway.

We are currently applying through CREGS + LINCAM PoC. Official Ceres pages list PoC support at £5,000-£20,000 and a 7-minute pitch format.

Official pages: Ceres Agri-Tech LINCAM webpages · accessed 24 Feb 2026.

Source -> Model -> Solve (explainable)

Real public context is transformed into transparent computation space.

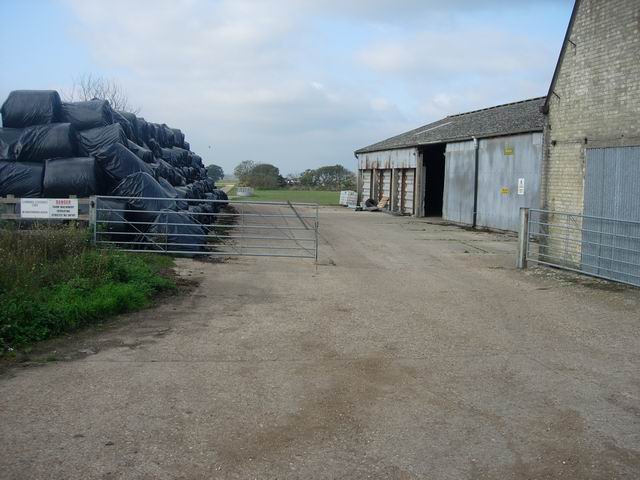
Cambridge University Farm real context
Public farmyard context photo used for explainable source-to-model mapping (demo context only; no private telemetry).
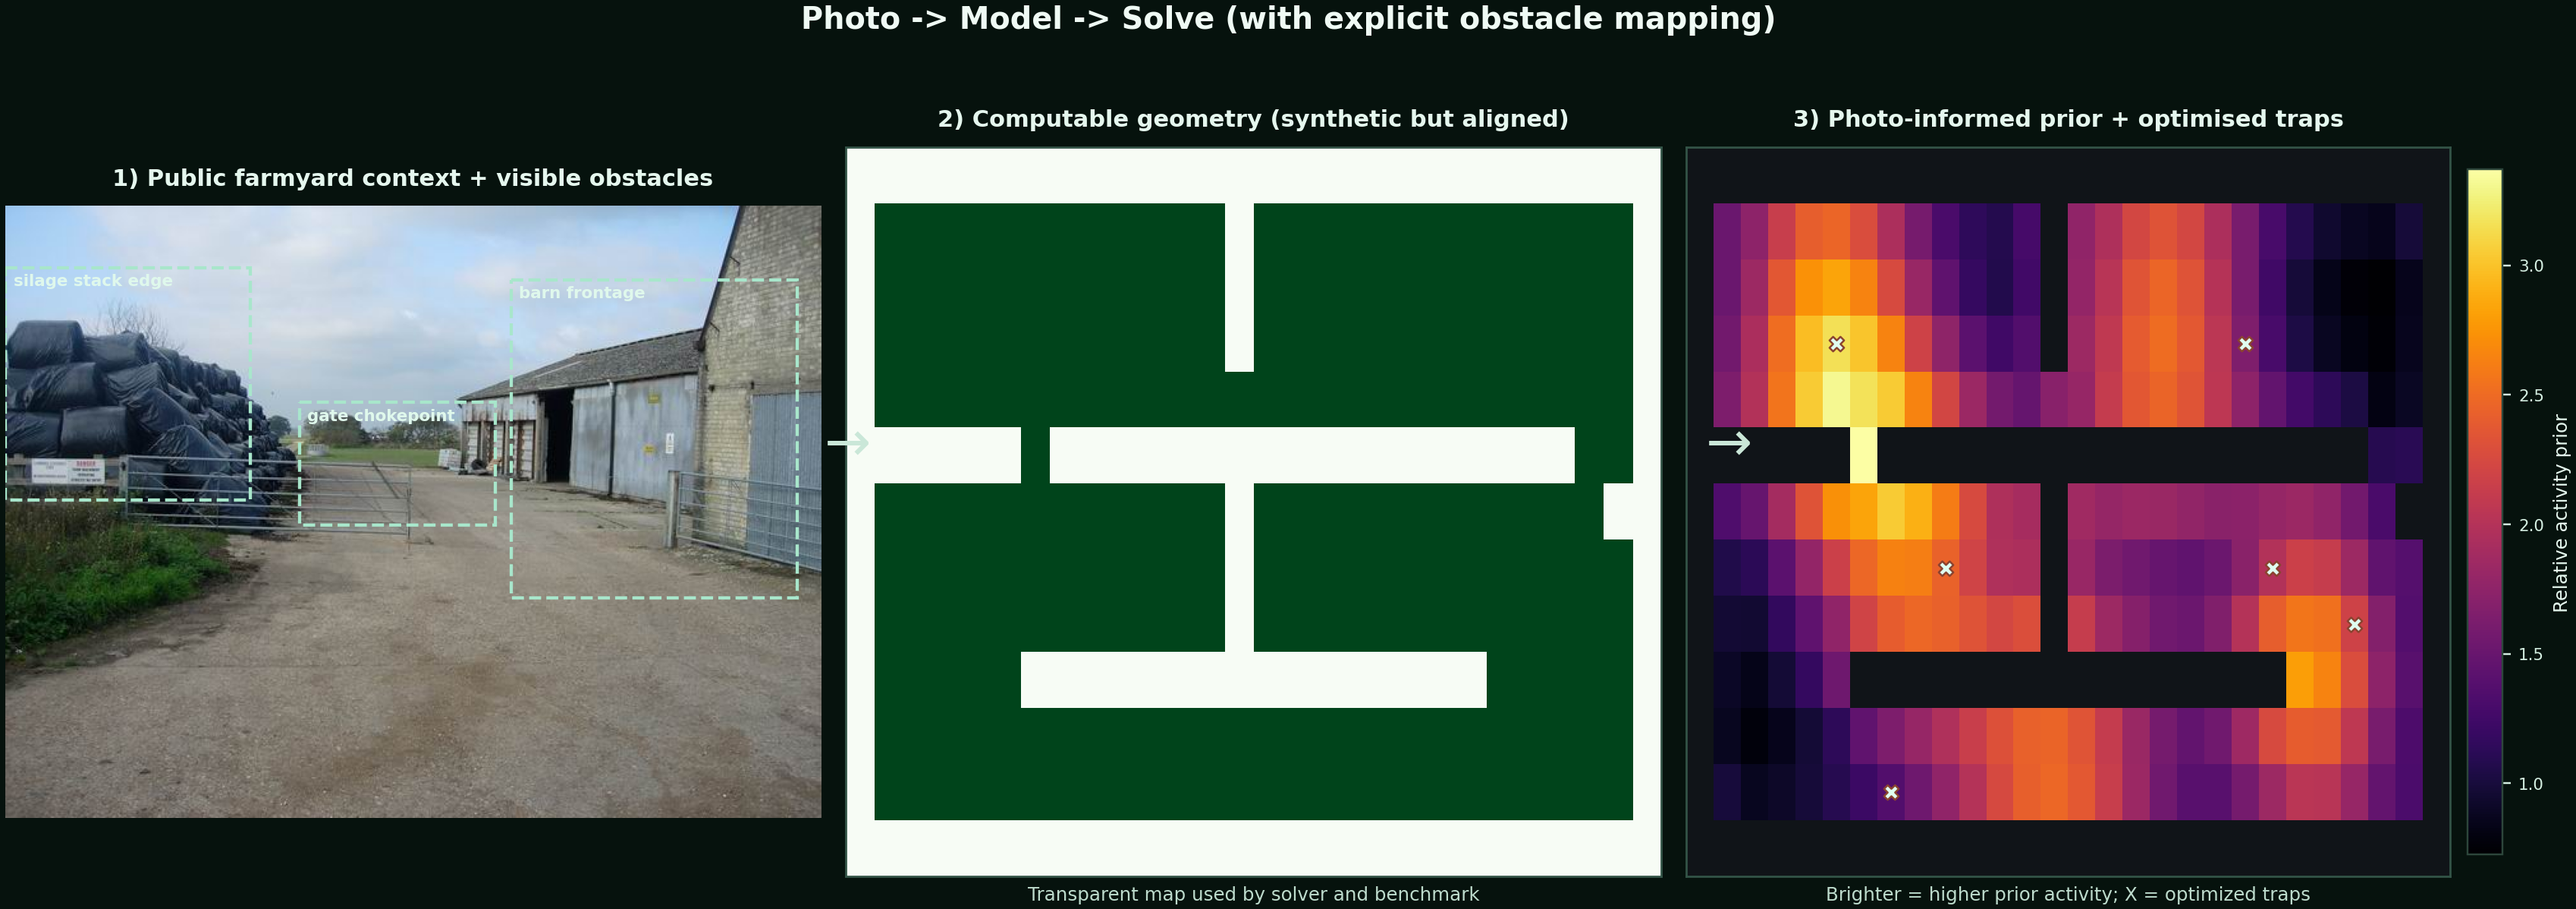
Conversion chain from photo to geometry to risk prior
Photo context -> synthetic walkable geometry -> photo-informed risk prior.
Optimized heatmap and trap positions
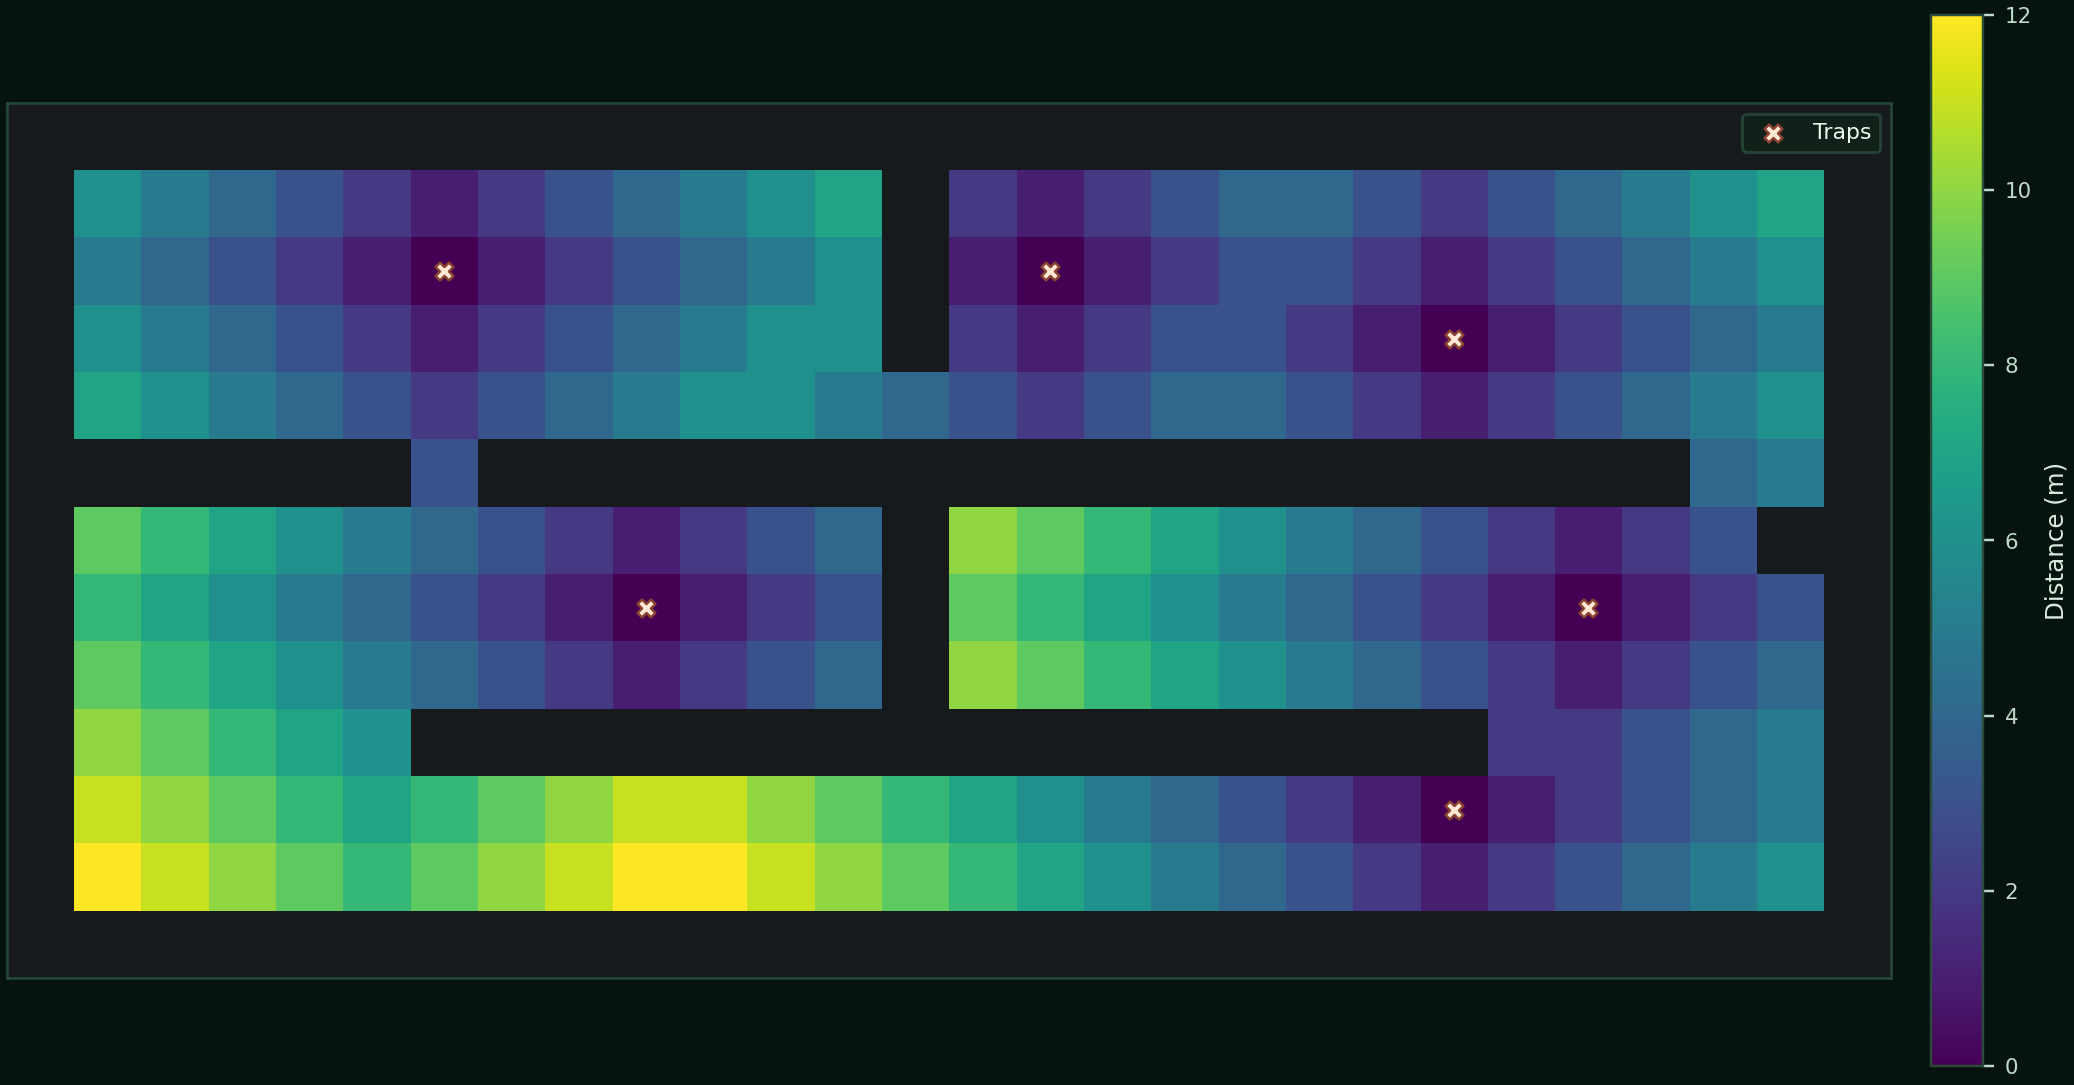
Optimized traps + distance heatmap used in live proof segment.

Live Operations

Use this section only for live mode. Pitch Safe can be presented without it.

API Setup

Auto-detection order: query -> saved -> config.json.

Solver Parameters

Map JSON

Run Controls

Tip: Solve first, then benchmark.

Run History

Optional evidence references for Q&A.